AI Humanoid Robot Teacher Sally Introduced in New York Schools
In an innovative move, Salamanca High School in New York has welcomed Sally, a 5-foot-2 humanoid robot, as an educational assistant for upper-grade students. This $57,000 robot boasts lifelike silicone skin and a meticulously designed appearance. The school district emphasizes that Sally is not intended to replace human teachers; instead, she operates within a closed AI system that ensures no student data is transmitted to her manufacturer.
Challenges Facing Today’s Robots
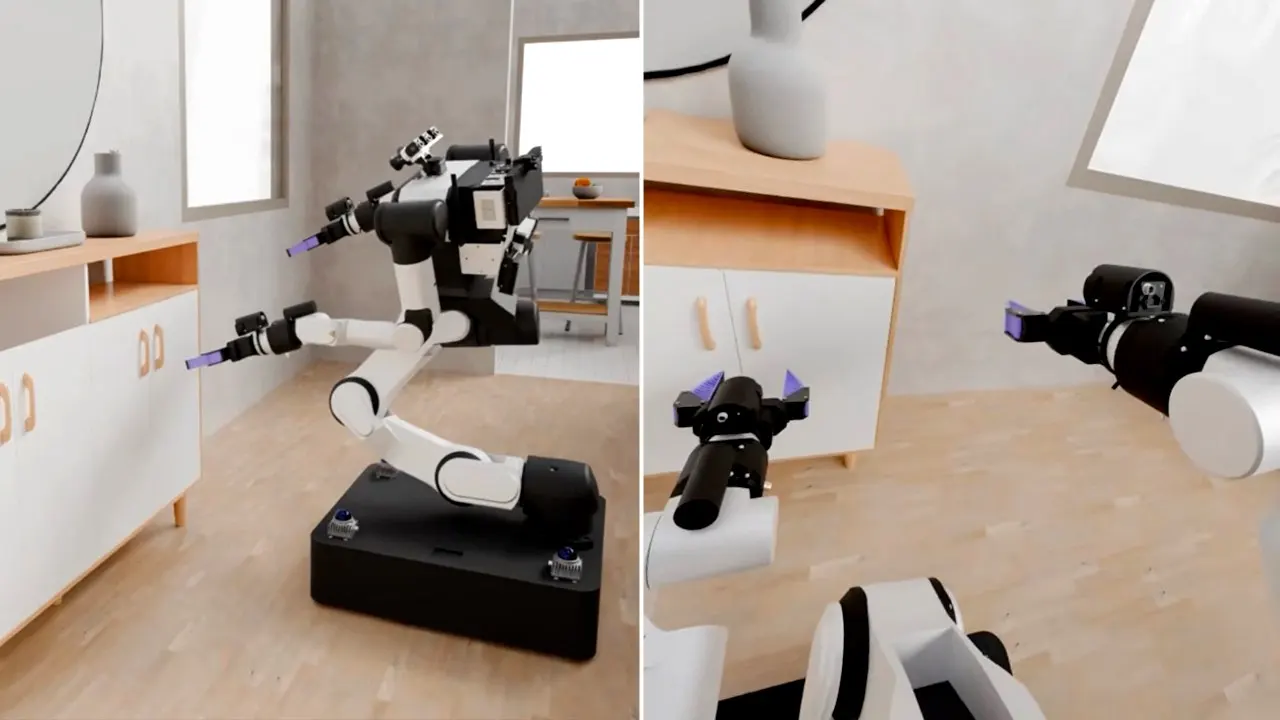
Consider a simple household task, like asking a robot to put a mug in a cabinet. It quickly becomes clear that what seems straightforward for us can pose challenges for robots. We know the mug’s location, can navigate around obstacles, and open the cabinet without much thought. For the robot, however, each step must be executed distinctly.
This sheds light on why many robots excel in demonstrations but still struggle with basic tasks in real-life settings. The ability to perform reliably in diverse conditions comes from extensive experience and hands-on training, which requires time and careful supervision.
MIT’s Virtual Training Innovations
Researchers at MIT’s Computer Science and Artificial Intelligence Laboratory, along with the Toyota Research Institute, are exploring virtual training as a solution. Their system, SceneSmith, can generate detailed 3D indoor environments from simple text prompts. This allows robots to rehearse tasks in these simulated spaces, helping to identify weak strategies before they face real-world situations.
The Significance of Virtual Training for Robots
Robots learn by doing, but creating an accurate representation of every room and its contents is challenging. Even minor changes, like a moved chair, can affect the outcome of a task. That’s why simulation offers a safer way to practice; robots can retry tasks without the risk of breaking real items. However, early simulations often lacked realism, missing the clutter and complexities of everyday life. SceneSmith aims to enhance this aspect, creating more relatable training environments.
How SceneSmith Operates
SceneSmith’s process begins with a straightforward text request. Researchers can design a space, like a garage with specific features. Three AI agents collaborate to develop the space: the designer creates, critics assess realism, and an orchestrator manages the project’s progress.
The building occurs layer by layer, starting with the foundational layout, adding furniture, and finally incorporating movable objects. Critics also help ensure that everything feels appropriate, with the orchestrator having the option to revert to earlier stages as needed.
Once the design is complete, SceneSmith adds physics to manage how objects interact, transforming the space from a mere 3D model into a functional environment where robots can practice tasks like opening cabinets or handling different items.
Creating Interactive Virtual Objects
Providing realistic scenarios involves more than designing believable environments; it requires interactive objects that respond to manipulation. For instance, SceneSmith enables the creation of cabinets with functional doors, alongside movable objects with defined physical properties, like weight and texture. These elements influence how robots behave when they interact with the objects.
Diverse Training Environments Created
So far, the team has generated over 1,300 scenes, including typical settings like bedrooms and hotels, as well as unique environments such as pottery stores or game rooms. This variety allows robots to encounter different challenges and tasks, which is vital for preparing them for real-world environments filled with unpredictability.
Improving Robot Decision-Making
SceneSmith serves as a testing ground for robots’ operational policies—guidelines directing their actions based on observations. The researchers have created specific evaluation scenes for robots to test their performance, allowing for large-scale assessments without the need for continuous human oversight.
Real-World Testing Continues
Even with a realistic appearance, virtual rooms can sometimes lead to unexpected behavior in robots. Therefore, the researchers have physically tested SceneSmith by placing robots into these scenes with real-time instructions. Early tests showed promising results as robots successfully performed tasks like moving fruits simply from verbal prompts.
Positive Feedback on SceneSmith’s Design
In a comparison study, 205 participants overwhelmingly favored SceneSmith, noting its improved realism and alignment with their requests. But, ultimately, successful robot performance remains the key measure of effectiveness.
The Future of Virtual Robot Training
SceneSmith’s potential lies in its ability to prepare home robots for a complex, dynamic environment. Developers get the chance to refine robotic movements while staying within a safe, simulated setting before the robots interact with real-life scenarios where things are often unpredictable.
This foundational work is essential because as robots are designed for day-to-day tasks, they must learn to navigate real-world obstacles effectively. The road ahead still necessitates rigorous real-world testing, but SceneSmith offers a significant leap forward in training methodologies. It presents a critical resource for developers working to create robots capable of functioning seamlessly within homes.